COMPARISON WORKSPACE · FACTUAL, NOT RANKED
Compare with context.
Choose two to four passports. Values remain attached to their original field and operating scope.
COMPARE 2–4 ROBOTS
Select platforms
Values stay attached to their published field, operating scope, and configuration. Evidence can be opened from each comparison cell.
ROBOT VISUALS
Visual scale uses verified published heights only; images do not establish technical facts.
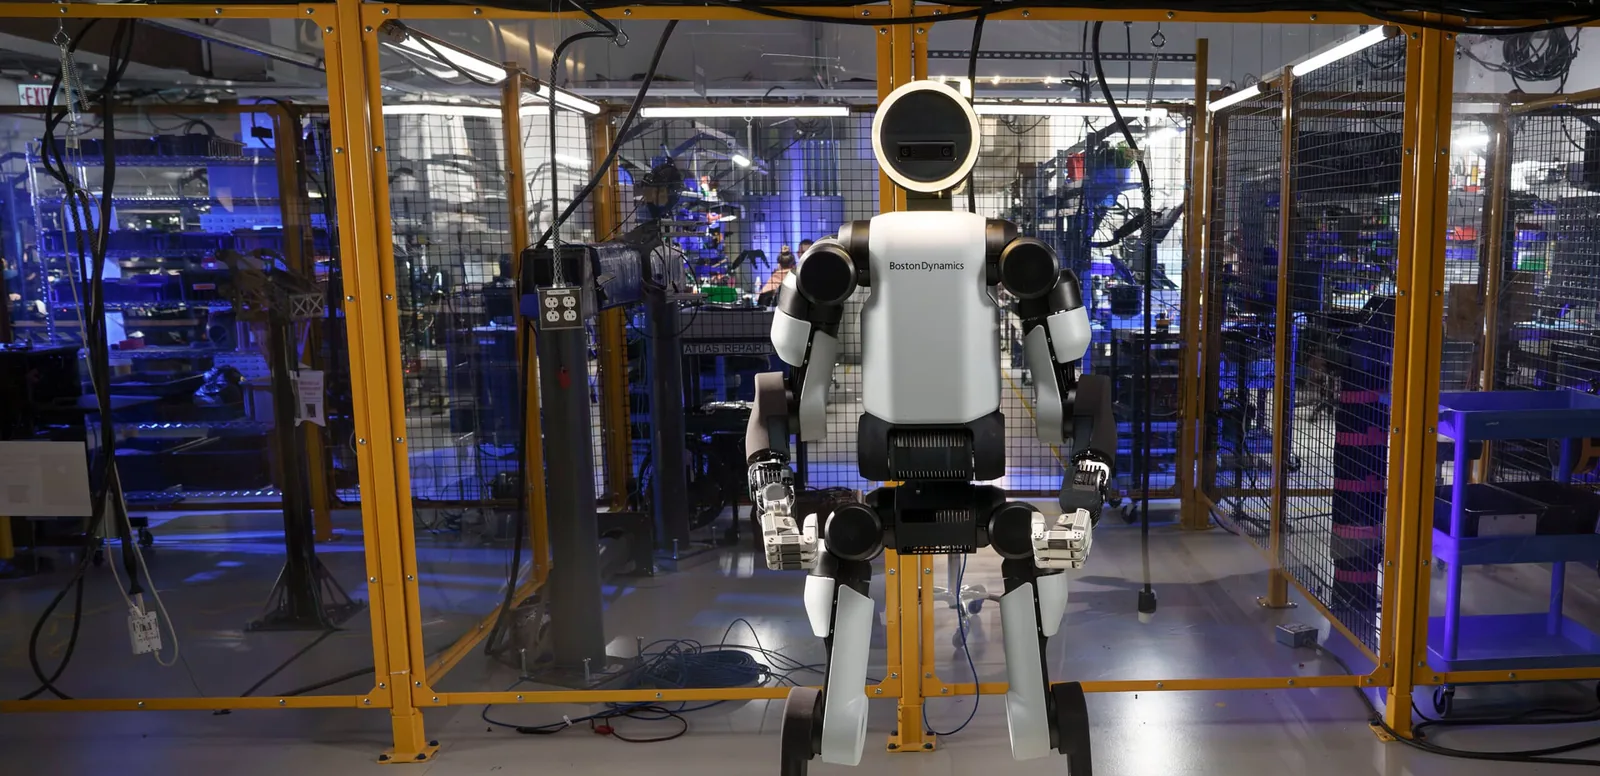
VISUAL NOT YET VERIFIED
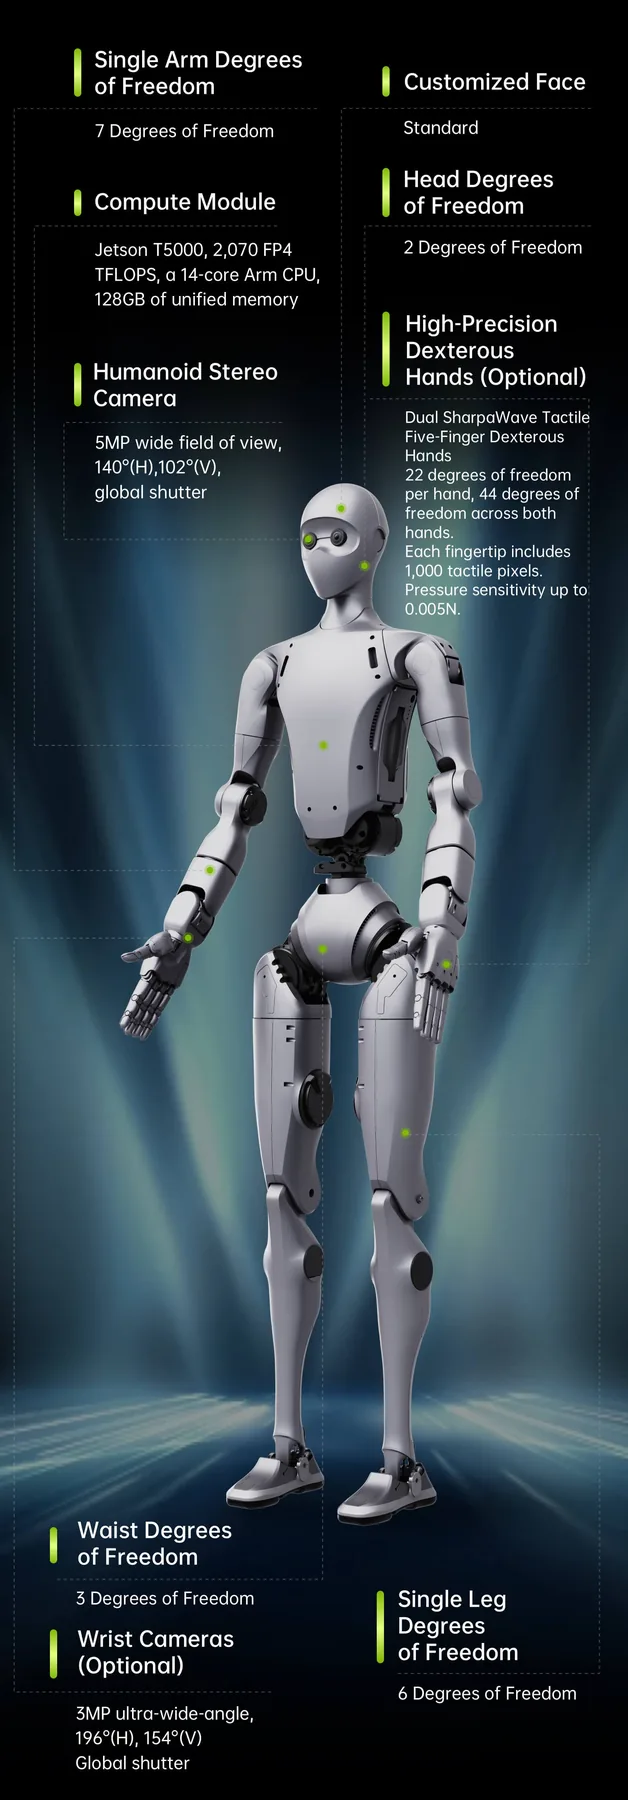
| Passport fact and scope | Boston DynamicsAtlas | Fourier IntelligenceGR-2 | Unitree RoboticsH2 PlusEvidence not yet traced | XPENGIRONConflict recorded |
|---|---|---|---|---|
| Battery capacity | Unknown | ≈ 950 WhScope not specifiedOptional dexterous handOfficial ≈ 950 WhScope not specifiedStandard handOfficial | Unknown | Unknown |
| Charge time | 1.5 hScope not specifiedConfiguration not establishedOfficial | ≈ 2 hScope not specifiedOptional dexterous handOfficial ≈ 2 hScope not specifiedStandard handOfficial | Unknown | Unknown |
| Battery runtime | 2 hHeavy liftingConfiguration not establishedOfficial 4 hOperating condition not specifiedConfiguration not establishedOfficial | ≈ 2 hOperating condition not specifiedOptional dexterous handOfficial ≈ 2 hOperating condition not specifiedStandard handOfficial | ≈ 3 hOperating condition not specifiedConfiguration not establishedOfficial | Unknown |
| Battery swap time | 3 minScope not specifiedConfiguration not establishedOfficial | Unknown | Unknown | Unknown |
| Compute module | Unknown | Intel Core i7 (14 cores)onboardOptional dexterous handOfficial Intel Core i7 (14 cores)onboardStandard handOfficial | NVIDIA Jetson T5000onboardConfiguration not establishedOfficial | Unknown |
| Compute performance | Unknown | Unknown | 2070 TFLOPSFP4 · sparseConfiguration not establishedOfficial | up to 2250 TOPSeffective computing powerConfiguration not establishedOfficial |
| Body degrees of freedom | Unknown | UnknownBody onlyStandard handNot established by approved evidence UnknownBody onlyOptional dexterous handNot established by approved evidence | Unknown | 76 DOFbodyConfiguration not establishedOfficial |
| Degrees of freedom claim | 56 DOFScope not specifiedConfiguration not establishedOfficial | Unknown | 31 motorsjoint motor countConfiguration not establishedOfficial | Unknown |
| Hand degrees of freedom | Unknown | 6 DOFPer handStandard handOfficial 12 DOFPer handOptional dexterous handOfficial | Unknown | 21 DOFPer handConfiguration not establishedOfficialConflict recorded |
| Total degrees of freedom | Unknown | UnknownWhole robotStandard handNot established by approved evidence UnknownWhole robotOptional dexterous handNot established by approved evidence | 75 DOFbody and handsConfiguration not establishedOfficial | UnknownWhole robotConfiguration not establishedNot established by approved evidence |
| Maximum total degrees of freedom | Unknown | up to 53 DOFWhole robotOptional dexterous handOfficial | Unknown | Unknown |
| Environment Operating Temperature C | -20–40 CScope not specifiedConfiguration not establishedOfficial | Unknown | Unknown | Unknown |
| Height | 1.90 mStandingConfiguration not establishedOfficial | 1.75 mStandingStandard handOfficial 1.75 mStandingOptional dexterous handOfficial | Unknown | Unknown |
| Mass | 90 kgScope not specifiedConfiguration not establishedOfficial | 63 kgScope not specifiedStandard handOfficial 63 kgScope not specifiedOptional dexterous handOfficial | Unknown | Unknown |
| Payload | 50 kginstantaneousConfiguration not establishedOfficial 20 kgOne handConfiguration not establishedOfficial 30 kgsustainedConfiguration not establishedOfficial | ≈ 3 kgOne handOptional dexterous handOfficial ≈ 3 kgOne handStandard handOfficial | 15 kgSingle armConfiguration not establishedOfficial 7 kgSingle armConfiguration not establishedOfficial | Unknown |
| Production status | Unknown | Unknown | Unknown | Mass production planned by end of 2026; deliveries planned for 2027planned productionConfiguration not establishedOfficial |
| Public availability | Unknown | Unknown | Unknown | Unknownpublic commercialConfiguration not establishedNot established by approved evidence |
| Maximum reach | 2.3 mworkingConfiguration not establishedOfficial | Unknown | Unknown | Unknown |
| Safety Ip Rating | IP67Scope not specifiedConfiguration not establishedOfficial | Unknown | Unknown | Unknown |
| Speed | Unknown | 1.39 m/sScope not specifiedOptional dexterous handOfficial 1.39 m/sScope not specifiedStandard handOfficial | Unknown | Unknown |
Each comparison value links to its supporting evidence. Source links open separately so the comparison stays in place.